아두이노 기반 보안 시스템: 스마트 모션 감지 & 알림
부품 및 소모품
| Arduino UNO | 1개 |
| 초음파 센서 HC-SR04 (일반) | 1개 |
| 서보 모터 (Tower Pro MG996R) | 1개 |
| 부저 | 1개 |
| 브레드보드 (일반) | 1개 |
| 수/암 점퍼 와이어 | 1세트 |
| 플라스틱 박스 | 1개 |
필수 도구
앱 및 온라인 서비스
- Arduino IDE
- Processing IDE
프로젝트 소개


소개
이 프로젝트는 아두이노 우노, 서보 모터, 초음파 센서, 피에조 부저로 구성된 아두이노 기반 보안 시스템입니다.
초음파 센서가 감지 범위 내 물체를 감지하면 부저가 작동합니다. 이 센서 데이터는 Processing IDE 소프트웨어로도 전송되어 그래픽 맵(레이더 화면)을 생성합니다.
서보 모터는 초음파 센서를 회전시켜 넓은 영역을 커버합니다.
꽤 간단한 프로젝트로 1시간 내에 완성 가능합니다.
제작 절차
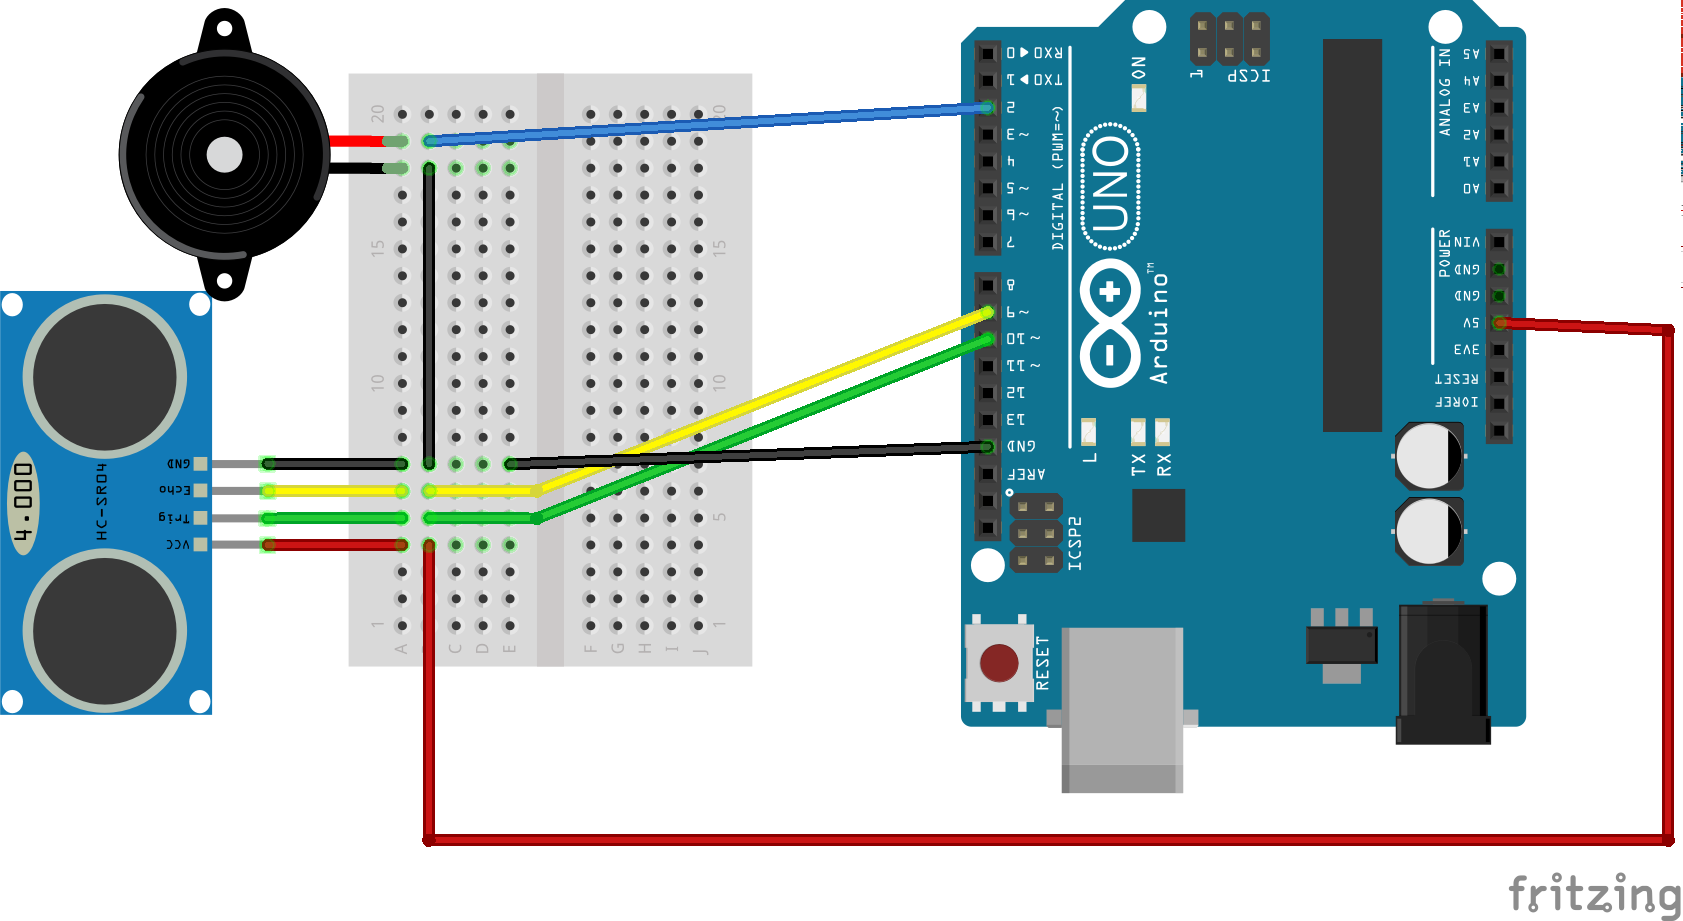
- 센서 Trig 핀 → 아두이노 핀 2
- 센서 Echo 핀 → 아두이노 핀 3
- 센서 Vcc → 5V, GND → GND
- 부저를 브레드보드에 장착: 양극 → 아두이노 핀 10, 음극 → GND
- 서보 모터: 검정/빨강선 → GND/5V, 노랑선(신호) → 아두이노 핀 9
- 아두이노 5V → 전원, GND → 접지
배선 완료 후 그림과 같이 전체 회로를 박스 안에 넣습니다. 이제 코딩 차례입니다.
코드
아두이노 코드 (Security System_IDE)
#include <Servo.h>

int tPin = 2;
int ePin = 3;
int buz = 10;
int d1, d2;
int i = 0;
int sdistance;
Servo myServo;

void setup() {
  Serial.begin(9600);
  pinMode(tPin, OUTPUT);
  pinMode(ePin, INPUT);
  pinMode(buz, OUTPUT);
  myServo.attach(9);
}

void loop() {
  // 서보를 0도에서 180도로 스윕
  for (i = 0; i <= 180; i += 10) {
    myServo.write(i);
    delay(30);
    d2 = calculateDistance();
    Serial.print(i);
    Serial.print(",");
    Serial.print(d2);
    Serial.print(".");
  }

  // 서보를 180도에서 0도로 역스윕
  for (i = 180; i > 0; i -= 10) {
    myServo.write(i);
    delay(30);
    d2 = calculateDistance();
    Serial.print(i);
    Serial.print(",");
    Serial.print(d2);
    Serial.print(".");
  }
}

int calculateDistance() {
  digitalWrite(tPin, HIGH);
  delayMicroseconds(10);  // 10μs 펄스 (원본의 delay(1000)은 오타로 보임)
  digitalWrite(tPin, LOW);
  d1 = pulseIn(ePin, HIGH);
  d2 = d1 * 0.0171821306;  // 거리 계산 (cm)

  if (d2 < 10) {
    digitalWrite(buz, HIGH);  // 10cm 이내면 부저 ON
  } else {
    digitalWrite(buz, LOW);
  }
  return d2;
}
Processing 코드 (레이더 시각화)
import processing.serial.*;
import java.awt.event.KeyEvent;
import java.io.IOException;

Serial myPort;
String angle = "";
String distance = "";
String data = "";
String noObject;
float pixsDistance;
int iAngle, iDistance;
int index1 = 0, index2 = 0;
PFont orcFont;

void setup() {
  size(1366, 768);  // 화면 해상도에 맞게 수정
  smooth();
  myPort = new Serial(this, "COM3", 9600);  // 포트 번호 확인 필요
  myPort.bufferUntil('.');
}

void draw() {
  fill(98, 245, 31);
  noStroke();
  fill(0, 4);
  rect(0, 0, width, height - height * 0.065);
  fill(98, 245, 31);

  drawRadar();
  drawLine();
  drawObject();
  drawText();
}

void serialEvent(Serial myPort) {
  data = myPort.readStringUntil('.');
  data = data.substring(0, data.length() - 1);
  index1 = data.indexOf(",");
  angle = data.substring(0, index1);
  distance = data.substring(index1 + 1, data.length());

  iAngle = int(angle);
  iDistance = int(distance);
}

void drawRadar() {
  pushMatrix();
  translate(width/2, height - height * 0.074);
  noFill();
  strokeWeight(2);
  stroke(98, 245, 31);

  // 원호 그리기
  arc(0, 0, width - width * 0.0625, width - width * 0.0625, PI, TWO_PI);
  arc(0, 0, width - width * 0.27, width - width * 0.27, PI, TWO_PI);
  arc(0, 0, width - width * 0.479, width - width * 0.479, PI, TWO_PI);
  arc(0, 0, width - width * 0.687, width - width * 0.687, PI, TWO_PI);

  // 각도 선 그리기
  line(-width/2, 0, width/2, 0);
  line(0, 0, (-width/2) * cos(radians(30)), (-width/2) * sin(radians(30)));
  line(0, 0, (-width/2) * cos(radians(60)), (-width/2) * sin(radians(60)));
  line(0, 0, (-width/2) * cos(radians(90)), (-width/2) * sin(radians(90)));
  line(0, 0, (-width/2) * cos(radians(120)), (-width/2) * sin(radians(120)));
  line(0, 0, (-width/2) * cos(radians(150)), (-width/2) * sin(radians(150)));
  line((-width/2) * cos(radians(30)), 0, width/2, 0);
  popMatrix();
}

void drawObject() {
  pushMatrix();
  translate(width/2, height - height * 0.074);
  strokeWeight(9);
  stroke(255, 10, 10);

  pixsDistance = iDistance * ((height - height * 0.1666) * 0.025);

  if (iDistance < 40) {  // 40cm 이내만 표시
    line(pixsDistance * cos(radians(iAngle)), -pixsDistance * sin(radians(iAngle)),
         (width - width * 0.505) * cos(radians(iAngle)), -(width - width * 0.505) * sin(radians(iAngle)));
  }
  popMatrix();
}

void drawLine() {
  pushMatrix();
  strokeWeight(9);
  stroke(30, 250, 60);
  translate(width/2, height - height * 0.074);
  line(0, 0, (height - height * 0.12) * cos(radians(iAngle)), -(height - height * 0.12) * sin(radians(iAngle)));
  popMatrix();
}

void drawText() {
  pushMatrix();
  if (iDistance > 40) {
    noObject = "Out of Range";
  } else {
    noObject = "In Range";
  }

  fill(0, 0, 0);
  noStroke();
  rect(0, height - height * 0.0648, width, height);
  fill(98, 245, 31);
  textSize(25);
  text("2cm", width - width * 0.3854, height - height * 0.0833);
  text("4cm", width - width * 0.281, height - height * 0.0833);
  text("6cm", width - width * 0.177, height - height * 0.0833);
  text("10cm", width - width * 0.0729, height - height * 0.0833);
  textSize(40);
  text("Akshay6766", width - width * 0.875, height - height * 0.0277);
  text("Angle: " + iAngle + " ", width - width * 0.48, height - height * 0.0277);
  text("Distance: ", width - width * 0.26, height - height * 0.0277);

  if (iDistance < 40) {
    text(" " + iDistance + " cm", width - width * 0.225, height - height * 0.0277);
  }

  textSize(25);
  fill(98, 245, 60);

  // 각도 레이블 그리기
  translate((width - width * 0.4994) + width/2 * cos(radians(30)), (height - height * 0.0907) - width/2 * sin(radians(30)));
  rotate(-radians(-60)); text("30", 0, 0); resetMatrix();

  translate((width - width * 0.503) + width/2 * cos(radians(60)), (height - height * 0.0888) - width/2 * sin(radians(60)));
  rotate(-radians(-30)); text("60", 0, 0); resetMatrix();

  translate((width - width * 0.507) + width/2 * cos(radians(90)), (height - height * 0.0833) - width/2 * sin(radians(90)));
  rotate(radians(0)); text("90", 0, 0); resetMatrix();

  translate(width - width * 0.513 + width/2 * cos(radians(120)), (height - height * 0.07129) - width/2 * sin(radians(120)));
  rotate(radians(-30)); text("120", 0, 0); resetMatrix();

  translate((width - width * 0.5104) + width/2 * cos(radians(150)), (height - height * 0.0574) - width/2 * sin(radians(150)));
  rotate(radians(-60)); text("150", 0, 0);
  popMatrix();
}
회로도